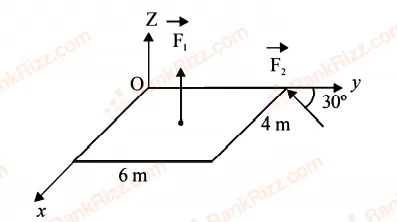
For force F ⃗ 1 : \text{For force } \vec{F}_1: For force F 1 : Position vector: r ⃗ 1 = 2 i ^ + 3 j ^ \text{Position vector: } \vec{r}_1 = 2\hat{i} + 3\hat{j} Position vector: r 1 = 2 i ^ + 3 j ^
Force vector (acting along z-axis): F ⃗ 1 = F k ^ \text{Force vector (acting along z-axis): } \vec{F}_1 = F\hat{k} Force vector (acting along z-axis): F 1 = F k ^
τ ⃗ 1 = r ⃗ 1 × F ⃗ 1 = ( 2 i ^ + 3 j ^ ) × ( F k ^ ) = 2 F ( − j ^ ) + 3 F ( i ^ ) = ( 3 i ^ − 2 j ^ ) F \vec{\tau}_1 = \vec{r}_1 \times \vec{F}_1 = (2\hat{i} + 3\hat{j}) \times (F\hat{k}) = 2F(-\hat{j}) + 3F(\hat{i}) = (3\hat{i} - 2\hat{j})F τ 1 = r 1 × F 1 = ( 2 i ^ + 3 j ^ ) × ( F k ^ ) = 2 F ( − j ^ ) + 3 F ( i ^ ) = ( 3 i ^ − 2 j ^ ) F
For force F ⃗ 2 : \text{For force } \vec{F}_2: For force F 2 : From the geometry of the slab, the point of application is on the y-axis at y = 6 m : \text{From the geometry of the slab, the point of application is on the y-axis at } y = 6\text{ m}: From the geometry of the slab, the point of application is on the y-axis at y = 6 m : r ⃗ 2 = 6 j ^ \vec{r}_2 = 6\hat{j} r 2 = 6 j ^
F ⃗ 2 = − F sin ( 30 ∘ ) i ^ − F cos ( 30 ∘ ) j ^ = − F 2 i ^ − F 3 2 j ^ \vec{F}_2 = -F\sin(30^\circ)\hat{i} - F\cos(30^\circ)\hat{j} = -\frac{F}{2}\hat{i} - \frac{F\sqrt{3}}{2}\hat{j} F 2 = − F sin ( 3 0 ∘ ) i ^ − F cos ( 3 0 ∘ ) j ^ = − 2 F i ^ − 2 F 3 j ^
τ ⃗ 2 = r ⃗ 2 × F ⃗ 2 = ( 6 j ^ ) × ( − F 2 i ^ − F 3 2 j ^ ) = − 3 F ( j ^ × i ^ ) − 3 3 F ( j ^ × j ^ ) \vec{\tau}_2 = \vec{r}_2 \times \vec{F}_2 = (6\hat{j}) \times \left(-\frac{F}{2}\hat{i} - \frac{F\sqrt{3}}{2}\hat{j}\right) = -3F(\hat{j} \times \hat{i}) - 3\sqrt{3}F(\hat{j} \times \hat{j}) τ 2 = r 2 × F 2 = ( 6 j ^ ) × ( − 2 F i ^ − 2 F 3 j ^ ) = − 3 F ( j ^ × i ^ ) − 3 3 F ( j ^ × j ^ )
Using the unit vector properties j ^ × i ^ = − k ^ and j ^ × j ^ = 0 : \text{Using the unit vector properties } \hat{j} \times \hat{i} = -\hat{k} \text{ and } \hat{j} \times \hat{j} = 0: Using the unit vector properties j ^ × i ^ = − k ^ and j ^ × j ^ = 0 : τ ⃗ 2 = 3 F k ^ \vec{\tau}_2 = 3F\hat{k} τ 2 = 3 F k ^
Total moment about point O: \text{Total moment about point O:} Total moment about point O:
τ ⃗ net = τ ⃗ 1 + τ ⃗ 2 = ( 3 i ^ − 2 j ^ ) F + 3 F k ^ = ( 3 i ^ − 2 j ^ + 3 k ^ ) F \vec{\tau}_{\text{net}} = \vec{\tau}_1 + \vec{\tau}_2 = (3\hat{i} - 2\hat{j})F + 3F\hat{k} = (3\hat{i} - 2\hat{j} + 3\hat{k})F τ net = τ 1 + τ 2 = ( 3 i ^ − 2 j ^ ) F + 3 F k ^ = ( 3 i ^ − 2 j ^ + 3 k ^ ) F